Hi, I'm Ruiqin Li.
I'm studying Electrical and Computer Engineering (ECE) at the National University of Singapore. Right now I'm going deeper into autonomous driving and active safety, AI sensors and VR/AR, deep reinforcement learning, embodied AI, world action models, and AI-related hardware optimization.
About
I'm at the Department of Electrical and Computer Engineering (ECE) at the National University of Singapore, going deeper into autonomous driving and active safety, AI sensors and VR/AR, deep reinforcement learning, embodied AI, world action models and AI-related hardware optimization.
In my spare time I build small tools I use regularly; most of what I've made is on GitHub.
Papers
-
Driving Like Yourself: A Benchmark for Closed-Loop Personalized End-to-End Autonomous Driving
ECCV 2026Person2Drive is a benchmark and platform for personalized end-to-end autonomous driving. It comes with a data collection system for building personalized driving datasets, metrics based on MMD and KL divergence for quantifying individual driving styles, and a personalization framework that fine-tunes only the trajectory prediction head — so the pretrained backbone stays intact and driving performance is preserved.
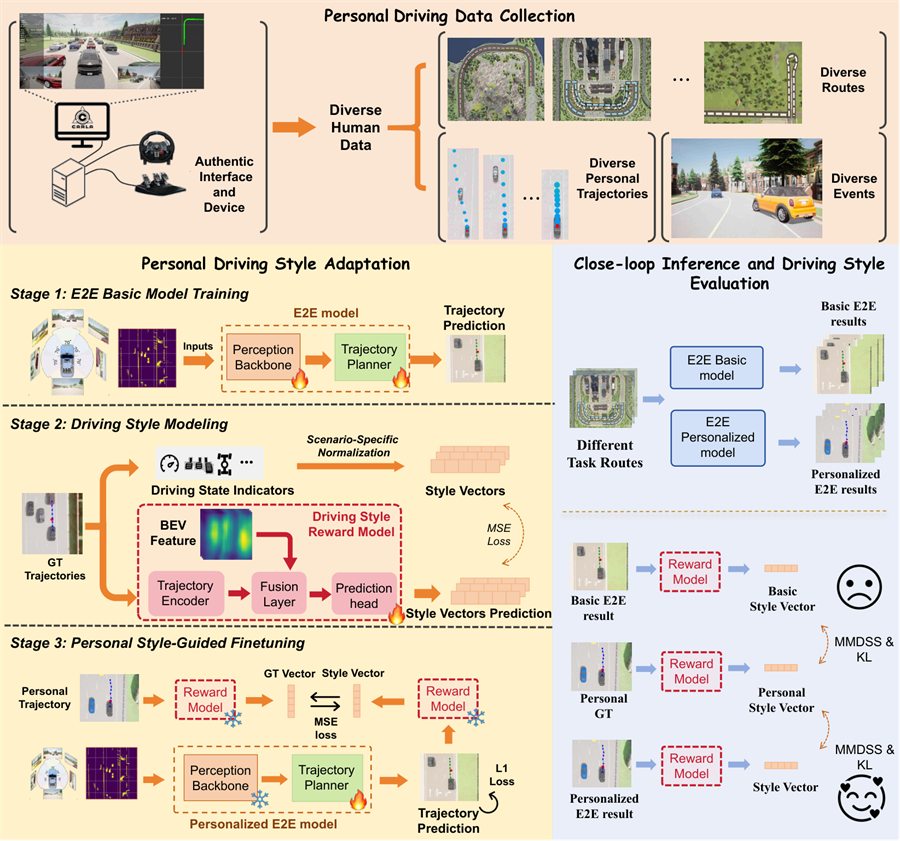
Person2Drive framework overview. Figure from Dong et al., ECCV 2026.
Projects
-
nice-reading-lens
Computer visionA phone on a stand points at your paper book; turn the page and the Chinese translation shows up on your PC. Page-turn detection, deskewing, two-page splitting, OCR and translation all run locally — translation goes through Ollama, so nothing leaves the machine.
-
live-interpreter
SpeechA lightweight real-time English to Chinese interpreter. It listens to your microphone and translates as you speak, entirely on your own machine — no cloud service involved.
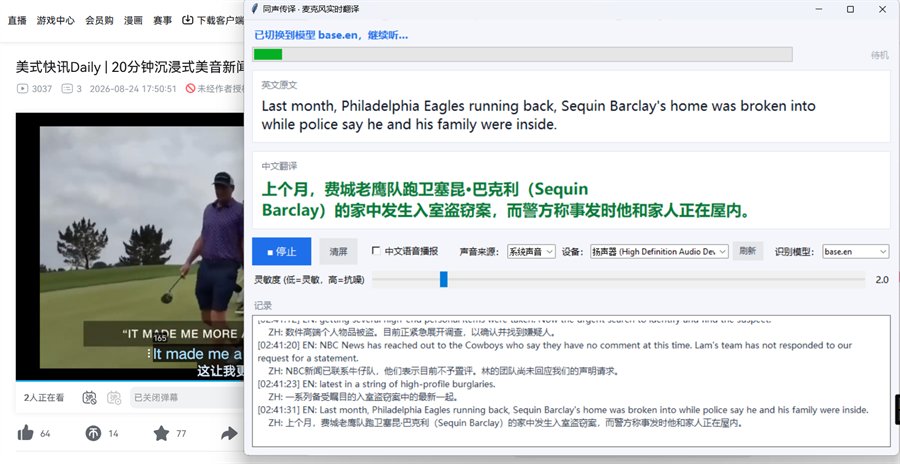
Running on a live news broadcast. -
CARLA-SB3-RL-Training-Environment
Reinforcement learningA training and evaluation environment for CARLA 0.10.0 built on Stable-Baselines3, with a control barrier function (CBF) safety filter wrapped around the learned policy: the filter solves a QP at every step to rewrite the action, and barrier violations are folded into the reward.
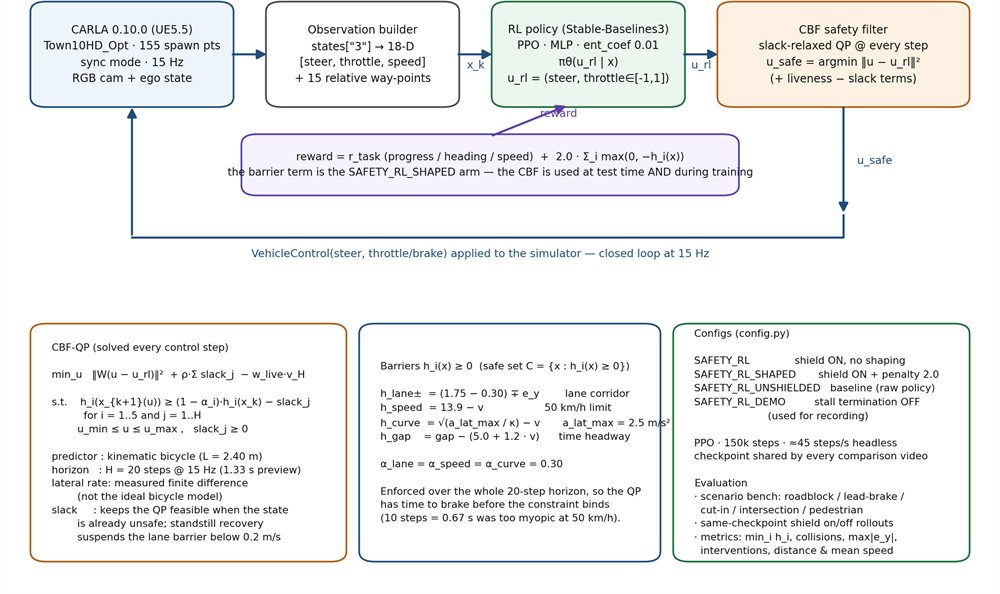
PPO policy with a CBF safety filter, closed loop in CARLA 0.10.0.
Contact
- Email liruiqin@u.nus.edu
- GitHub github.com/toyosatomimi98
- Scholar Google Scholar profile
- Based in Singapore